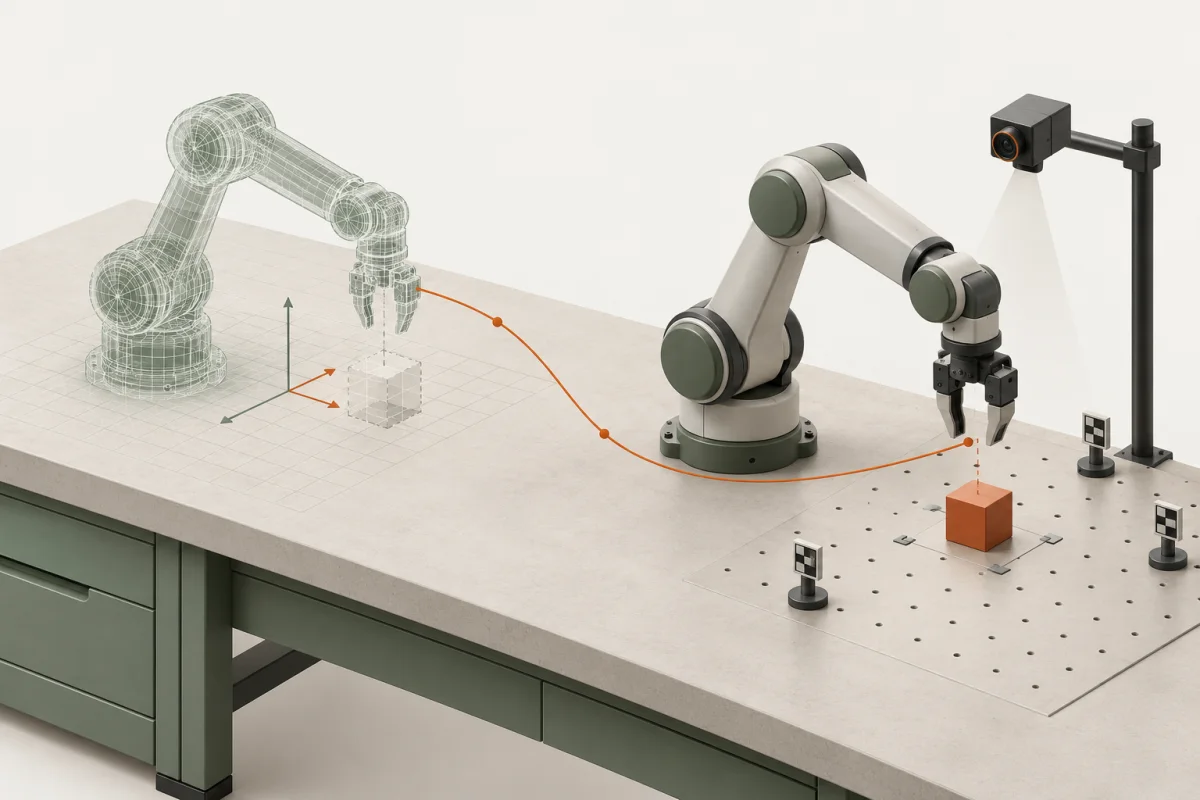
Your coding agent can help build a controller, integrate a model and run software simulation. The next question may require a physical robot: does the behavior work on the intended setup, and what actually happened?
Actuator Science is building an API for agents to request bounded physical experiments and retrieve original observations and results. We are gathering requirements for the first physical pilot.
Bring a question your project needs answered
You might need to evaluate a controller trained in MuJoCo or Isaac Lab, check an observation/action interface, collect demonstrations, or compare a simulated behavior with measured hardware behavior. Tell us which result would change your next decision.
The first physical setup is being prepared around a tabletop arm and camera. Hardware, sensors, motion limits and task suitability will need explicit qualification. Cloth, bimanual, dexterous and mobile experiments require additional capabilities and are not currently offered.
What would a useful experiment include?
- Your inputs: a controller or model, interface requirements and an exact question.
- An agreed setup: robot, tool, observations, starting state and permitted variation.
- A bounded run: reviewed local limits, finite execution and owner-approved cost before any paid work.
- Inspectable results: original observations, commands, timestamps, outcomes, failures and interventions.
This describes the intended pilot contract. Supported experiments, dates and pricing remain to be established. Your model and research decisions stay with you; private customer data would require explicit permission for any reuse.
Tell us what would make a pilot useful
Join the waitlist below to register your experiment category. For a concrete request, you can also email an experiment brief. This link opens a draft in your email app; you choose whether to send it. Start with a non-confidential description.
Project and controller:
Question to test:
Required robot, tool and sensors:
Evidence needed:
Current blocker:
Timing and indicative budget:
We use these requests to understand demand and assess possible pilot fit. A request is not a guarantee of compatibility, availability or a particular outcome.
Planning a first test? Read the simulation-to-hardware checklist or our SoftMimicGen research note.
EARLY ACCESS
IN DEVELOPMENTHelp shape the
first experiments.
We're building robot rooms that your agent can use through an API. Join the waitlist for pilot access and launch updates.
The rooms, prices and workflow on this site are concepts. Physical bookings and a hosted MCP connection are not available yet.